4cac0b1401
Artwork state and its bytes outlive a deleted entity until the next
prune (@daily), and the serving path consulted only item_artwork, so a
Subsonic id or a signed public token kept serving a removed entity's
image in the meantime. Master's readers loaded the entity first, so this
was a regression.

The check goes in serveHash, the one path that can hand back a found
row's bytes: absent rows are already unavailable, and the provisional
and disc paths load their entity to resolve at all. Doing it there
instead of per-handler also settles who owns the invariant. Subsonic had
worked around it with artworkAccessible, whose comment described the
service "bypassing the library and private-playlist filters"; that
workaround is now deleted, since the service resolves through the
request-scoped repositories and enforces the filters itself.

Because those repositories are ctx-scoped, each caller says what it
wants by what it passes: Subsonic hands over the request context and so
gets visibility as well as existence, while the public image route
elevates like the Jellyfin one already did -- a token is the
authorization there, and a visibility check would hide a shared private
playlist, the very case shares exist for.

Two supporting fixes. albumRepository.Exists and mediaFileRepository
.Exists used the plain exists() helper, which applies no library filter,
so they reported rows in libraries the caller cannot see; they now count
through applyLibraryFilter as CountAll and artistRepository.Exists
already do. Neither had a production caller. RadioRepository gained the
Exists it lacked.

Tests follow the layers: the service refuses a found row whose entity is
gone, the repositories hide rows the caller may not see, and the
handlers only assert the context they hand over. Jellyfin needed no
change -- resolveArtworkID probes the entity tables, so a deleted item
yields an empty artwork id -- but that protection was incidental and
untested, so it is pinned now.

Navidrome Music Server 



Navidrome is an open source web-based music collection server and streamer. It gives you freedom to listen to your music collection from any browser or mobile device. It's like your personal Spotify!
Note: The master branch may be in an unstable or even broken state during development.
Please use releases instead of
the master branch in order to get a stable set of binaries.
Check out our Live Demo!
Any feedback is welcome! If you need/want a new feature, find a bug or think of any way to improve Navidrome, please file a GitHub issue or join the discussion in our Subreddit. If you want to contribute to the project in any other way (ui/backend dev, translations, themes), please join the chat in our Discord server.
Installation
See instructions on the project's website
Cloud Hosting
PikaPods has partnered with us to offer you an officially supported, cloud-hosted solution. A share of the revenue helps fund the development of Navidrome at no additional cost for you.

Features
- Handles very large music collections
- Streams virtually any audio format available
- Reads and uses all your beautifully curated metadata
- Great support for compilations (Various Artists albums) and box sets (multi-disc albums)
- Multi-user, each user has their own play counts, playlists, favourites, etc...
- Very low resource usage
- Multi-platform, runs on macOS, Linux and Windows. Docker images are also provided
- Ready to use binaries for all major platforms, including Raspberry Pi
- Automatically monitors your library for changes, importing new files and reloading new metadata
- Supports lyrics from sidecar .ttml, .yaml/.yml Lyricsfile, .elrc, .lrc, .srt, .txt files and embedded TTML, Enhanced LRC, LRC, SRT, and plain-text tags (via
lyricspriority) - Themeable, modern and responsive Web interface based on Material UI
- Compatible with all Subsonic/Madsonic/Airsonic clients
- Transcoding on the fly. Can be set per user/player. Opus encoding is supported
- Translated to various languages
Translations
Navidrome uses POEditor for translations, and we are always looking for more contributors
Documentation
All documentation can be found in the project's website: https://www.navidrome.org/docs. Here are some useful direct links:
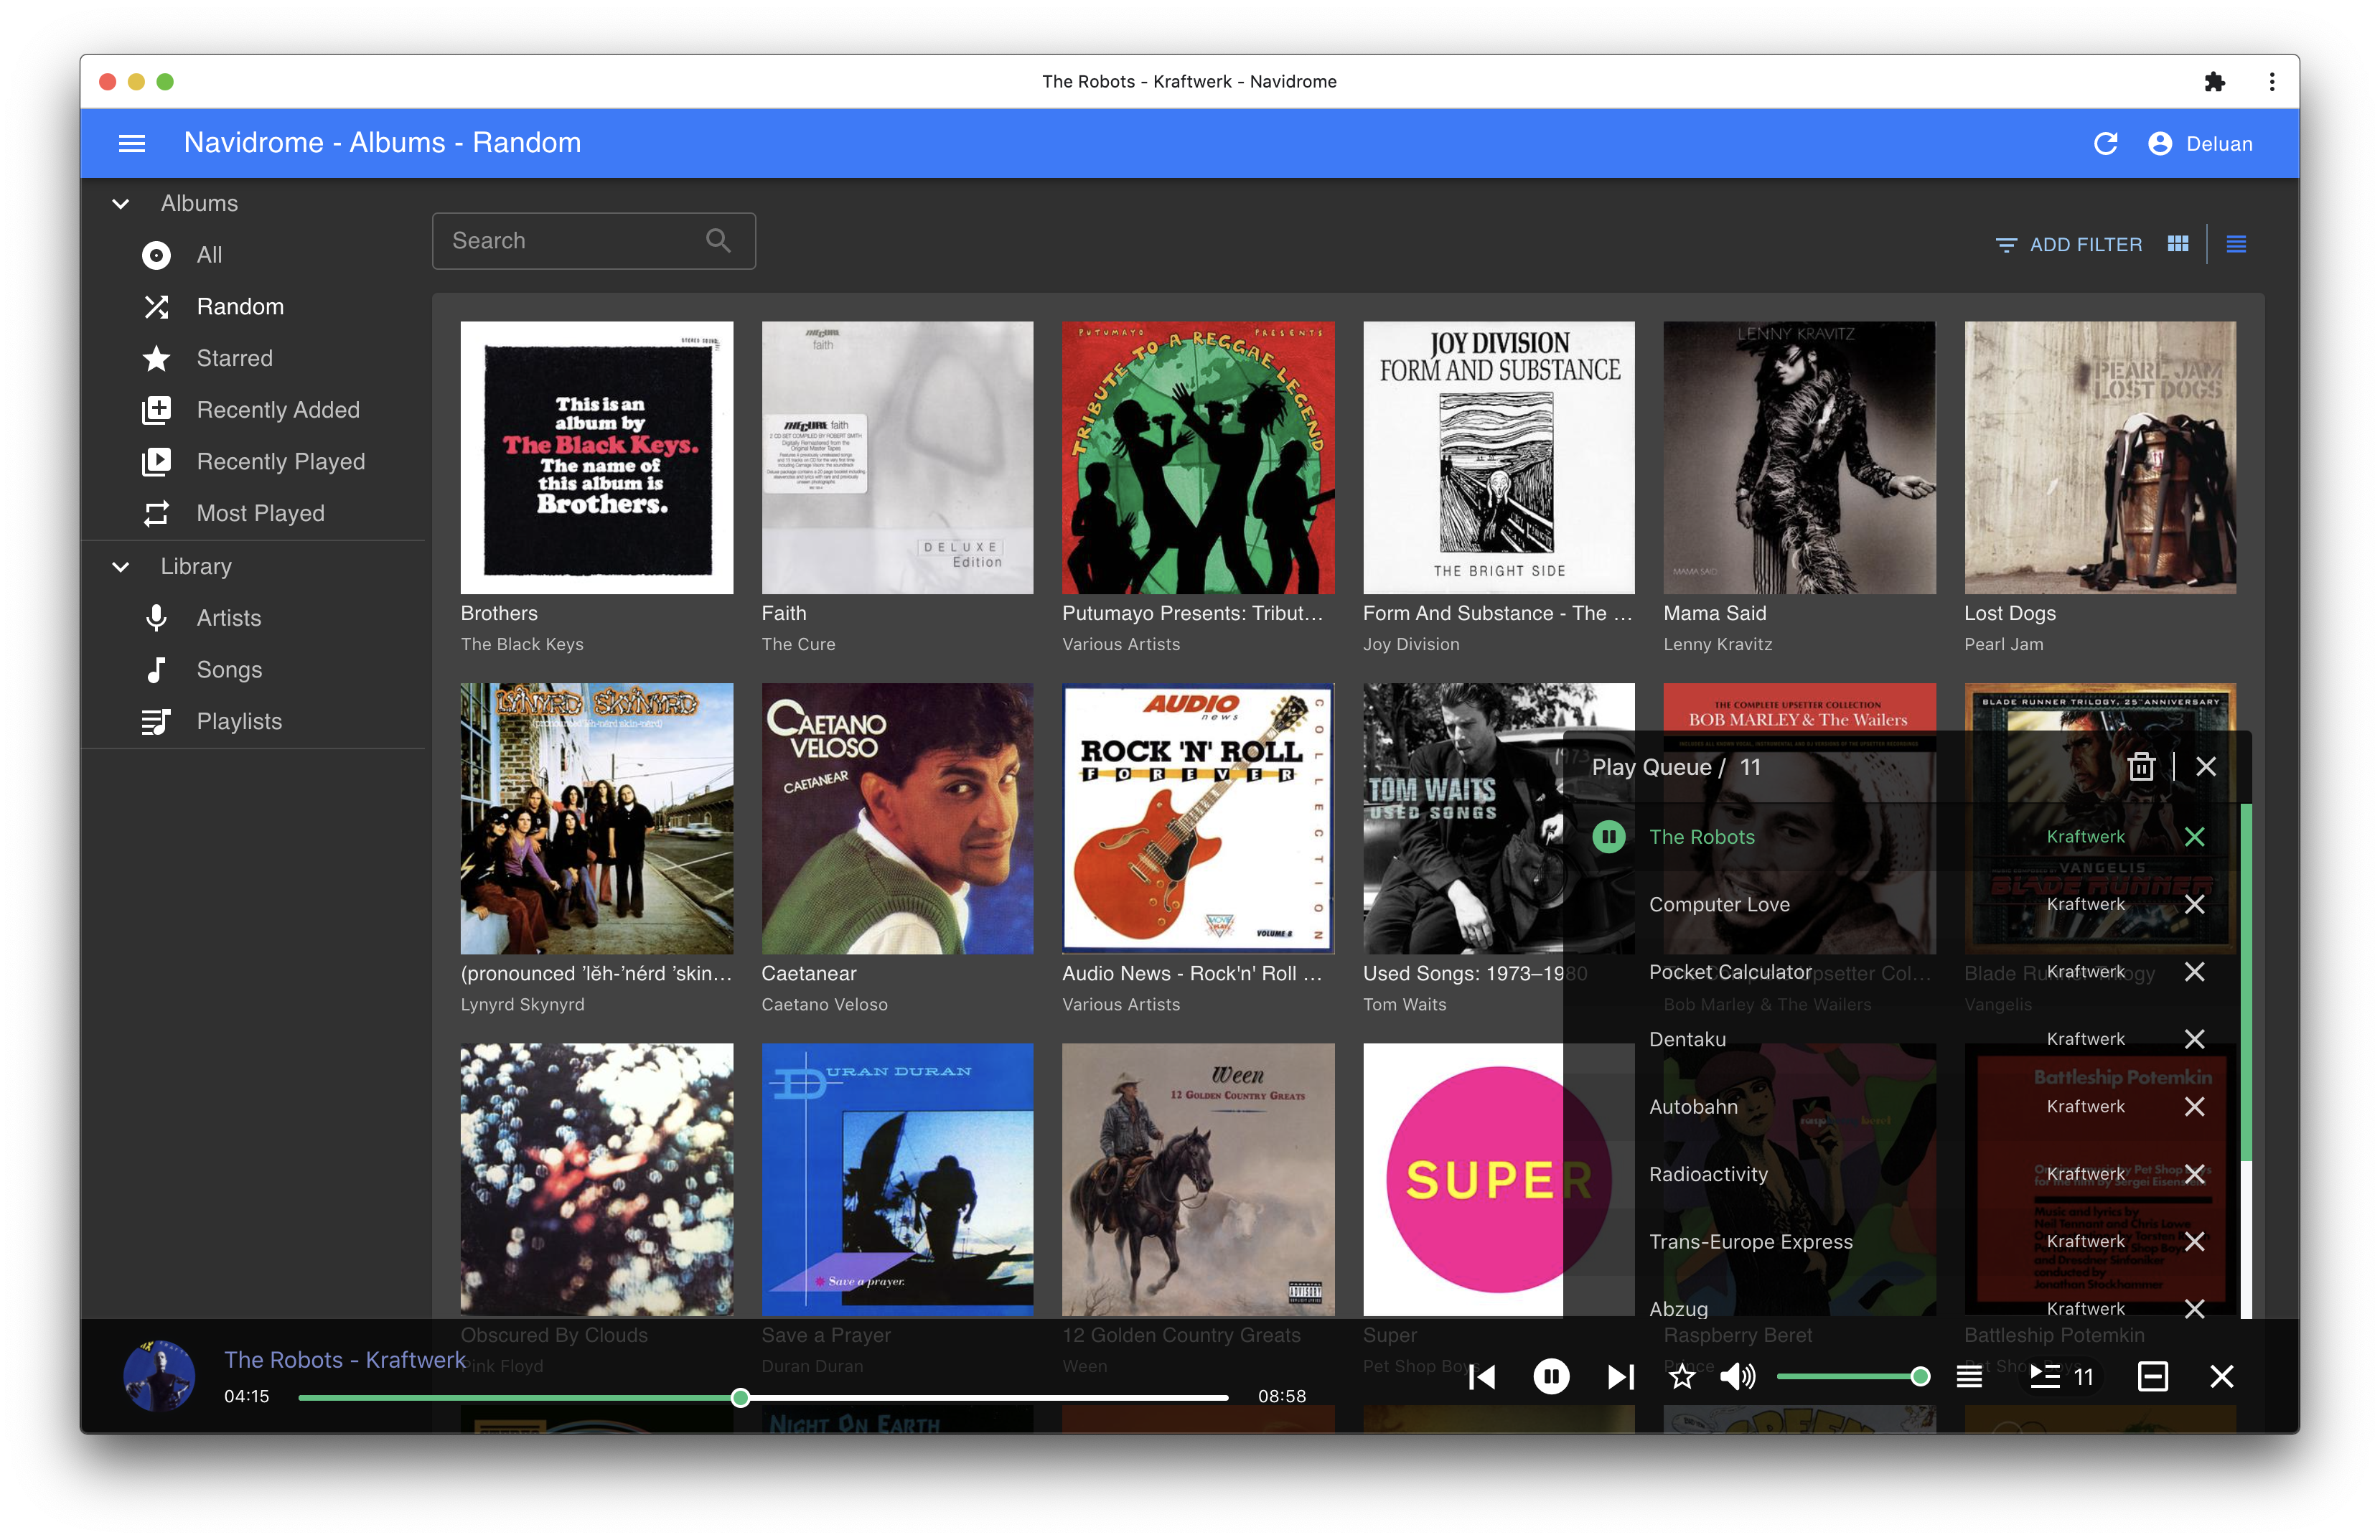
Screenshots